AUTONOMOUS EXPLORATION OF UNKNOWN ENVIRONMENTS USING ENTRANCE DETECTION, CLASSIFICATION, AND MULTI-TARGET ENTRANCE ORGANIZATION
DOI:
https://doi.org/10.11113/jurnalteknologi.v89.24309Keywords:
Unknown environment, exploration, multiple entrance, evaluate entrance, optimum sequenceAbstract
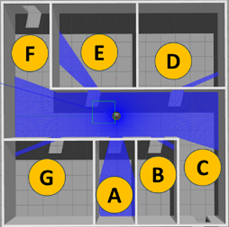
Exploration in unknown environments remains a significant challenge in robotics and artificial intelligence, particularly in navigating dynamic (always changing) and complex terrains such as indoor areas with multiple rooms and obstacles. Traditional static target algorithms struggle with dynamic changes and lack the capability to verify detected entrances or junctions as actual free spaces. Additionally, these methods process one target at a time, increasing the risk of missing critical exploration areas. The need for advanced algorithms that adapt to dynamic entrance, evaluate detected entrance, sort multiple entrances, and efficiently explore based on importance is essential for advancing both research and practical applications. To address these challenges, this paper introduces the Multiple Target Evaluation Node (M-TEN) framework, inspired by Frontier Exploration. Using LiDAR data, M-TEN detects possible entrances, verifies true entrances with 99% accuracy, and optimally generates a sequence for multiple entrances. Performance was tested in a 10m x 10m simulation environment with two map configurations. The results demonstrate that M-TEN enables mobile robots to explore unknown environments efficiently, achieving 94.5% mapping coverage within 3.8 minutes compared to manually controlled and basic frontier exploration approach. This framework enhances exploration accuracy, reduces time, and ensures reliable target evaluation and sorting.
References
[1] M. Rybczak, N. Popowniak, and A. Lazarowska, “A Survey of Machine Learning Approaches for Mobile Robot Control,” Jan. 01, 2024, Multidisciplinary Digital Publishing Institute (MDPI). DOI: 10.3390/robotics13010012.
[2] C. Benson, I. C. Obasi, D. V. Akinwande, and C. Ile, “The impact of interventions on health, safety and environment in the process industry,” Heliyon, vol. 10, no. 1, Jan. 2024, DOI: 10.1016/j.heliyon.2023.e23604.
[3] M. Andreoni, W. T. Lunardi, G. Lawton, and S. Thakkar, “Enhancing Autonomous System Security and Resilience With Generative AI: A Comprehensive Survey,” IEEE Access, vol. 12, pp. 109470–109493, 2024, DOI: 10.1109/ACCESS.2024.3439363.
[4] A. Thakur and S. K. Mishra, “An in-depth evaluation of deep learning-enabled adaptive approaches for detecting obstacles using sensor-fused data in autonomous vehicles,” Jul. 01, 2024, Elsevier Ltd. DOI: 10.1016/j.engappai.2024.108550.
[5] M. R. Wayahdi, S. H. N. Ginting, and D. Syahputra, “Greedy, A-Star, and Dijkstra’s Algorithms in Finding Shortest Path,” International Journal of Advances in Data and Information Systems, vol. 2, no. 1, pp. 45–52, Feb. 2021, DOI: 10.25008/ijadis.v2i1.1206.
[6] O. R. Chandra and W. Istiono, “A-star Optimization with Heap-sort Algorithm on NPC Character,” Indian J Sci Technol, vol. 15, no. 35, pp. 1722–1731, 2022, DOI: 10.17485/IJST/v15i35.857.
[7] B. Yamauchi, “A Frontier-Based Approach for Autonomous Exploration,” 1997.
[8] N. Thakur, E. Bhattacharjee, R. Jain, B. Acharya, and Y. C. Hu, “Deep learning-based parking occupancy detection framework using ResNet and VGG-16,” Multimed Tools Appl, vol. 83, no. 1, pp. 1941–1964, Jan. 2024, DOI: 10.1007/s11042-023-15654-w.
[9] M. Antonazzi, M. Luperto, N. A. Borghese, and N. Basilico, “Development and Adaptation of Robotic Vision in the Real-World: the Challenge of Door Detection,” Jan. 2024, [Online]. Available: http://arxiv.org/abs/2401.17996
[10] Akos Ferenc Kungl, “Robust learning algorithms for spiking and rate-based neural networks,” 2020.
[11] I. Maksymova, C. Steger, and N. Druml, “Review of LiDAR Sensor Data Acquisition and Compression for Automotive Applications,” MDPI AG, Dec. 2018, p. 852. DOI: 10.3390/proceedings2130852.
[12] N. D. Quadros, “Unlocking the Characteristics of Bathymetric LiDAR Sensors,” 2013. [Online]. Available: www.lidarnews.com
[13] B. Quintana, S. A. Prieto, A. Adán, and F. Bosché, “Door detection in 3D coloured point clouds of indoor environments,” Autom Constr, vol. 85, pp. 146–166, Jan. 2018, DOI: 10.1016/j.autcon.2017.10.016.
[14] A. C. Murillo, J. Košecká, J. J. Guerrero, and C. Sagüés, “Visual door detection integrating appearance and shape cues,” Rob Auton Syst, vol. 56, no. 6, pp. 512–521, Jun. 2008, DOI: 10.1016/j.robot.2008.03.003.
[15] T. A. Pham, M. Delalandre, S. Barrat, and J. Y. Ramel, “Accurate junction detection and characterization in line-drawing images,” Pattern Recognit, vol. 47, no. 1, pp. 282–295, Jan. 2014, DOI: 10.1016/j.patcog.2013.06.027.
[16] R. Mu˜noz et al., “Door-detection using computer vision and fuzzy logic,” Granada, 2004.
[17] H. Brehier, A. Breloy, C. Ren, and G. Ginolhac, “Through the Wall Radar Imaging via Kronecker-structured Huber-type RPCA,” Signal Processing, vol. 214, Jan. 2024, DOI: 10.1016/j.sigpro.2023.109228.
[18] Y. Wang, X. Shao, W. Yao, B. Zhang, G. Sun, and L. Wu, “EHSP: An Efficient Heuristic Sampling-Based Planner for Autonomous UAV Exploration,” IEEE Sens J, 2024, DOI: 10.1109/JSEN.2024.3462494.
[19] L. A. Fagundes, A. G. Caldeira, M. B. Quemelli, F. N. Martins, and A. S. Brandão, “Analytical Formalism for Data Representation and Object Detection with 2D LiDAR: Application in Mobile Robotics,” Sensors, vol. 24, no. 7, Apr. 2024, DOI: 10.3390/s24072284.
[20] B. Rolf et al., “A review on unsupervised learning algorithms and applications in supply chain management,” 2024, Taylor and Francis Ltd. DOI: 10.1080/00207543.2024.2390968.
[21] Q. Zhou and B. Sun, “Adaptive K-means clustering based under-sampling methods to solve the class imbalance problem,” Data Inf Manag, vol. 8, no. 3, Sep. 2024, DOI: 10.1016/j.dim.2023.100064.
[22] X. Li, M. Wei, and S. Chen, “PointSmile: Point Self-supervised Learning via Curriculum Mutual Information,” Jan. 2023, DOI: 10.1007/s11432-023-4085-9.
[23] N. R. Sasmita et al., “Decision Tree versus k-NN: A Performance Comparison for Air Quality Classification in Indonesia,” Infolitika Journal of Data Science, vol. 2, no. 1, pp. 9–16, May 2024, DOI: 10.60084/ijds.v2i1.179.
[24] P. K. Sarswat, R. S. Singh, and S. V. S. H. Pathapati, “Real time electronic-waste classification algorithms using the computer vision based on Convolutional Neural Network (CNN): Enhanced environmental incentives,” Resour Conserv Recycl, vol. 207, Aug. 2024, DOI: 10.1016/j.resconrec.2024.107651.
[25] J. Gui et al., “A Survey on Self-supervised Learning: Algorithms, Applications, and Future Trends,” IEEE Trans Pattern Anal Mach Intell, 2024, DOI: 10.1109/TPAMI.2024.3415112.
[26] M. Balestra et al., “LiDAR Data Fusion to Improve Forest Attribute Estimates: A Review,” Current Forestry Reports, vol. 10, no. 4, pp. 281–297, Aug. 2024, DOI: 10.1007/s40725-024-00223-7.
[27] S. O. Azarkasb and S. H. Khasteh, “Eligibility traces in an autonomous soccer robot with obstacle avoidance and navigation policy,” Appl Soft Comput, vol. 164, Oct. 2024, DOI: 10.1016/j.asoc.2024.111889.
[28] B. Kizielewicz, T. Tomczyk, M. Gandor, and W. Sałabun, “Subjective weight determination methods in multi-criteria decision-making: a systematic review,” in Procedia Computer Science, Elsevier B.V., 2024, pp. 5396–5407. DOI: 10.1016/j.procs.2024.09.673.
[29] C. Wei, J. Wu, Y. Xia, and Z. Ji, “Fast autonomous exploration with sparse topological graphs in large-scale environments,” Int J Intell Robot Appl, vol. 8, no. 1, pp. 111–121, Mar. 2024, DOI: 10.1007/s41315-023-00318-7.
[30] T. Zhao, X. Lin, F. He, and H. Dai, “Robotic Sorting Systems: Robot Management and Layout Design Optimization,” Apr. 2024, [Online]. Available: http://arxiv.org/abs/2404.04832
[31] K. Karur, N. Sharma, C. Dharmatti, and J. E. Siegel, “A Survey of Path Planning Algorithms for Mobile Robots,” Vehicles, vol. 3, no. 3, pp. 448–468, Sep. 2021, DOI: 10.3390/vehicles3030027.
Downloads
Published
Issue
Section
License
Copyright of articles that appear in Jurnal Teknologi belongs exclusively to Penerbit Universiti Teknologi Malaysia (Penerbit UTM Press). This copyright covers the rights to reproduce the article, including reprints, electronic reproductions, or any other reproductions of similar nature.